HyperLux

Overview over HyperLux features. Each section building on the previous one. The first run downloads scenes and JIT-compiles eight renderer configurations.
%pip install -q "hyperlux[examples]" torch matplotlibScene, camera, frame
scene = hyperlux.Scene()
scene.add_object(hyperlux.primitives.box(size=(6, 6, 0.1), color=(0.5, 0.5, 0.55)), hyperlux.make_transform(position=(0, 0, -0.55)))
scene.add_object(hyperlux.primitives.box(size=(1, 1, 1), color=(0.9, 0.35, 0.1)), hyperlux.make_transform(orientation_wxyz=(0.92, 0, 0, 0.38)))
scene.add_light(hyperlux.SceneLight.point((2, 1, 3), (4, 4, 4), radius=0.3))
renderer = hyperlux.HyperLux(width=1024, height=1024)
renderer.init(scene)
renderer.set_cameras(renderer.camera(position=(3, 1.5, 1.5), look_at=(0, 0, 0), fov=50))
renderer.render()
show([renderer.outputs[RGB()].read()[0]], columns=1, size=8)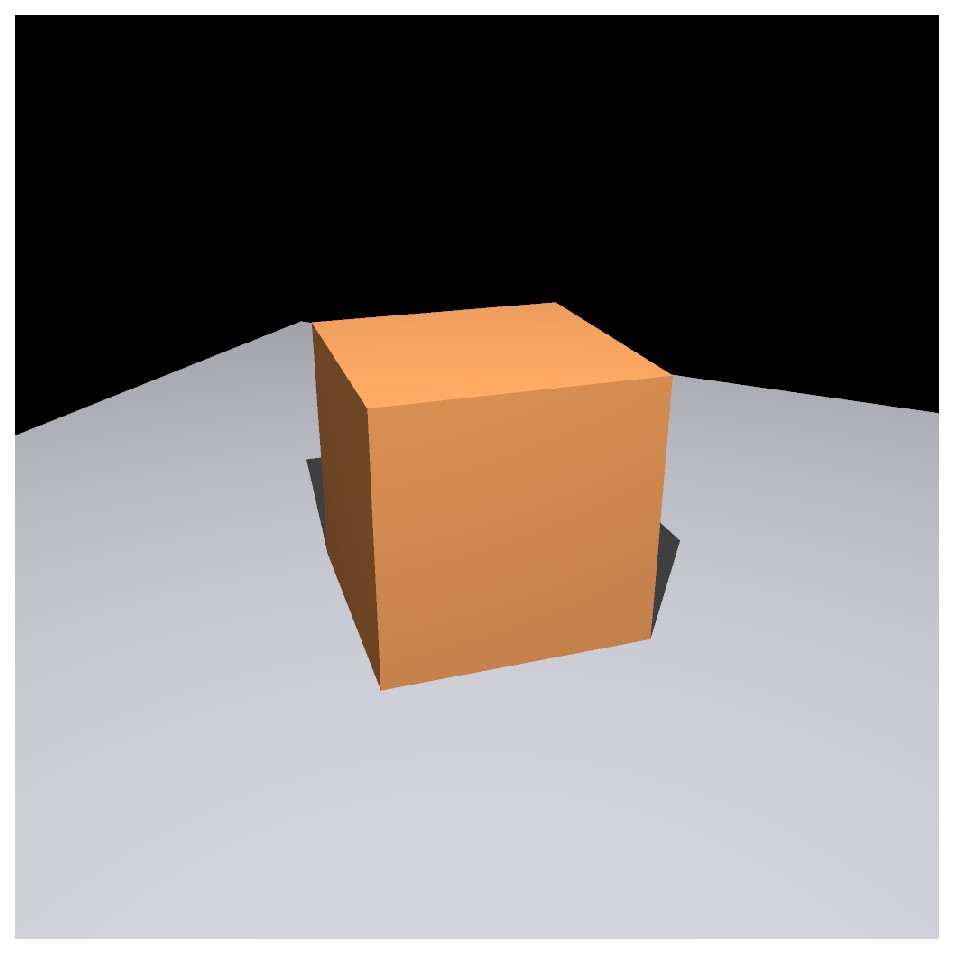
print(renderer.backend, renderer.config.key())
print(renderer.config)
studio = hyperlux.HyperLux(config=renderer.config)
optix bb98de75c1536dd3
Config(width=1024, height=1024, cameras=(CameraSpec(name='camera', outputs=(RGB(format='rgba8'),)),), batch_size=1, num_probes=1, fidelity='veryhigh', motion_blur_samples=1, anti_aliasing_grid=2, num_overlays=0, max_overlay_instances=0, max_overlays_per_camera=0, dynamic_motion_blur=False)
Materials, lights, environment
quad = np.array([[0, -0.4, -0.4], [0, 0.4, -0.4], [0, 0.4, 0.4], [0, -0.4, 0.4]], np.float32)
faces = np.array([[0, 1, 2], [0, 2, 3]], np.int32)
materials = hyperlux.Scene()
materials.add_object(hyperlux.primitives.box(size=(8, 8, 0.1), color=(0.5, 0.5, 0.55)), hyperlux.make_transform(position=(0, 0, -1.5)))
for row, roughness in enumerate((0.05, 0.4, 1.0)):
    for column, metallic in enumerate((0.0, 0.5, 1.0)):
        swatch = hyperlux.Object(f"metallic {metallic} roughness {roughness}")
        swatch.add_mesh(hyperlux.Mesh(quad, faces, color=(0.9, 0.5, 0.3), normals=np.tile(np.float32([1, 0, 0]), (4, 1)), tex_coords=quad[:, 1:] + 0.5, metallic=metallic, roughness=roughness))
        materials.add_object(swatch, hyperlux.make_transform(position=(0, 1 - column, 0.9 - 0.9 * row)))
glow = hyperlux.Object("emissive")
glow.add_mesh(hyperlux.Mesh(quad * 0.6, faces, color=(0, 0, 0), emissive=(0.2, 1.5, 3)))
glow.add_light(hyperlux.SceneLight.point((0.3, 0, 0), (0.1, 0.5, 1), attenuation=(1, 0, 1)))
materials.add_object(glow, hyperlux.make_transform(position=(0, -2, 0)))
materials.add_light(hyperlux.SceneLight.directional((0.8, 0.2, 0.57), (0.8, 0.8, 0.75), radius=0.05))
materials.add_light(hyperlux.SceneLight.spot((3, -2, 2), (-0.73, 0.49, -0.49), (2.5, 2.5, 2.5), cos_inner_cone=0.95, cos_outer_cone=0.85, radius=0.2))
materials.set_environment(ambient=(0.15, 0.15, 0.2), background=(0.02, 0.03, 0.05))
studio.init(materials)
studio.set_cameras(studio.camera(position=(4, 0, 0.3), look_at=(0, 0, 0), fov=60))
studio.render()
show([studio.outputs[RGB()].read()[0]], columns=1)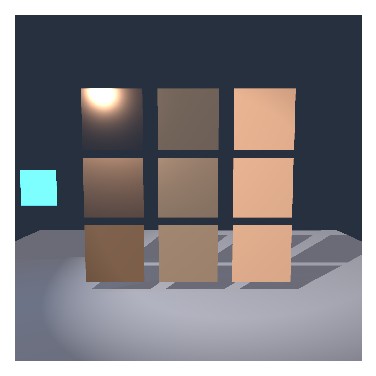
Fidelity tiers
tiers = []
for fidelity in hyperlux.FIDELITY:
    tier = hyperlux.HyperLux(width=256, height=256, fidelity=fidelity)
    tier.init(materials)
    tier.set_cameras(studio.camera(position=(4, 0, 0.3), look_at=(0, 0, 0), fov=60))
    tier.render()
    tiers.append(tier.outputs[RGB()].read()[0])
show(tiers, hyperlux.FIDELITY)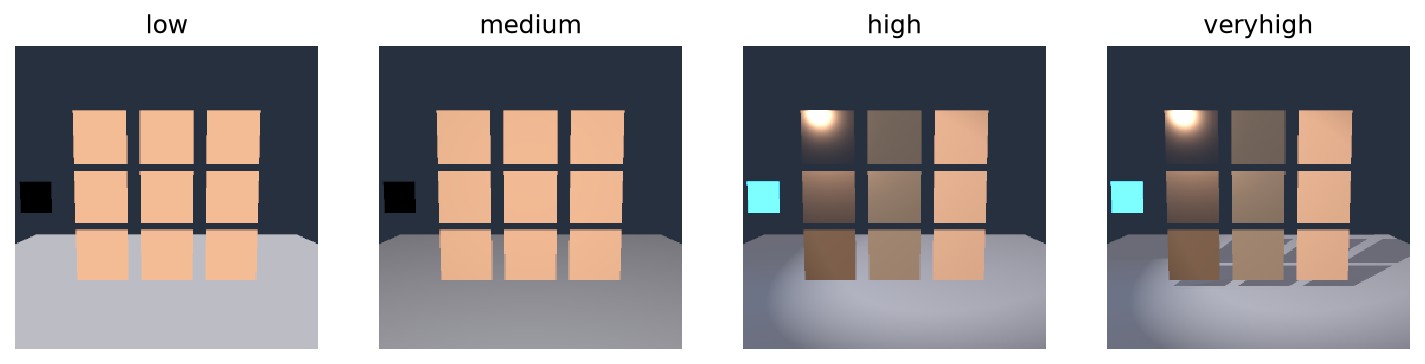
Anti-aliasing and motion blur
smooth = hyperlux.HyperLux(width=256, height=256, motion_blur_samples=8)
smooth.init(scene)
camera_open, camera_close = (renderer.camera(position=(3, y, 1.5), look_at=(0, 0, 0), fov=50) for y in (1.5, 1.9))
aliased = hyperlux.HyperLux(width=256, height=256, anti_aliasing_grid=1)
aliased.init(scene)
aliased.set_cameras(camera_open)
aliased.render()
smooth.set_cameras(camera_open)
smooth.render()
still = smooth.outputs[RGB()].read()[0]
smooth.set_motion_blur_cameras(camera_open, camera_close)
smooth.render_launch()
smooth.render_sync()
crop = np.s_[72:136, 64:128]
show([aliased.outputs[RGB()].read()[0][crop], still[crop], smooth.outputs[RGB()].read()[0][crop]], ("aliased", "2x2 anti-aliasing", "+ 8-sample motion blur"), columns=3)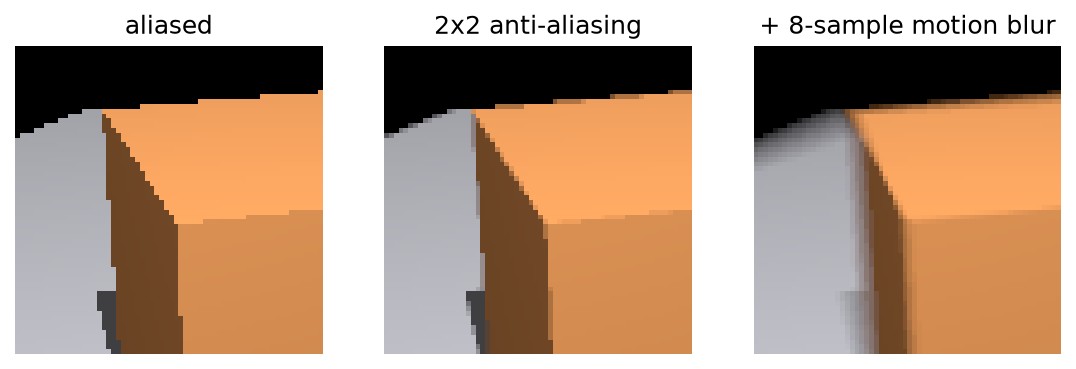
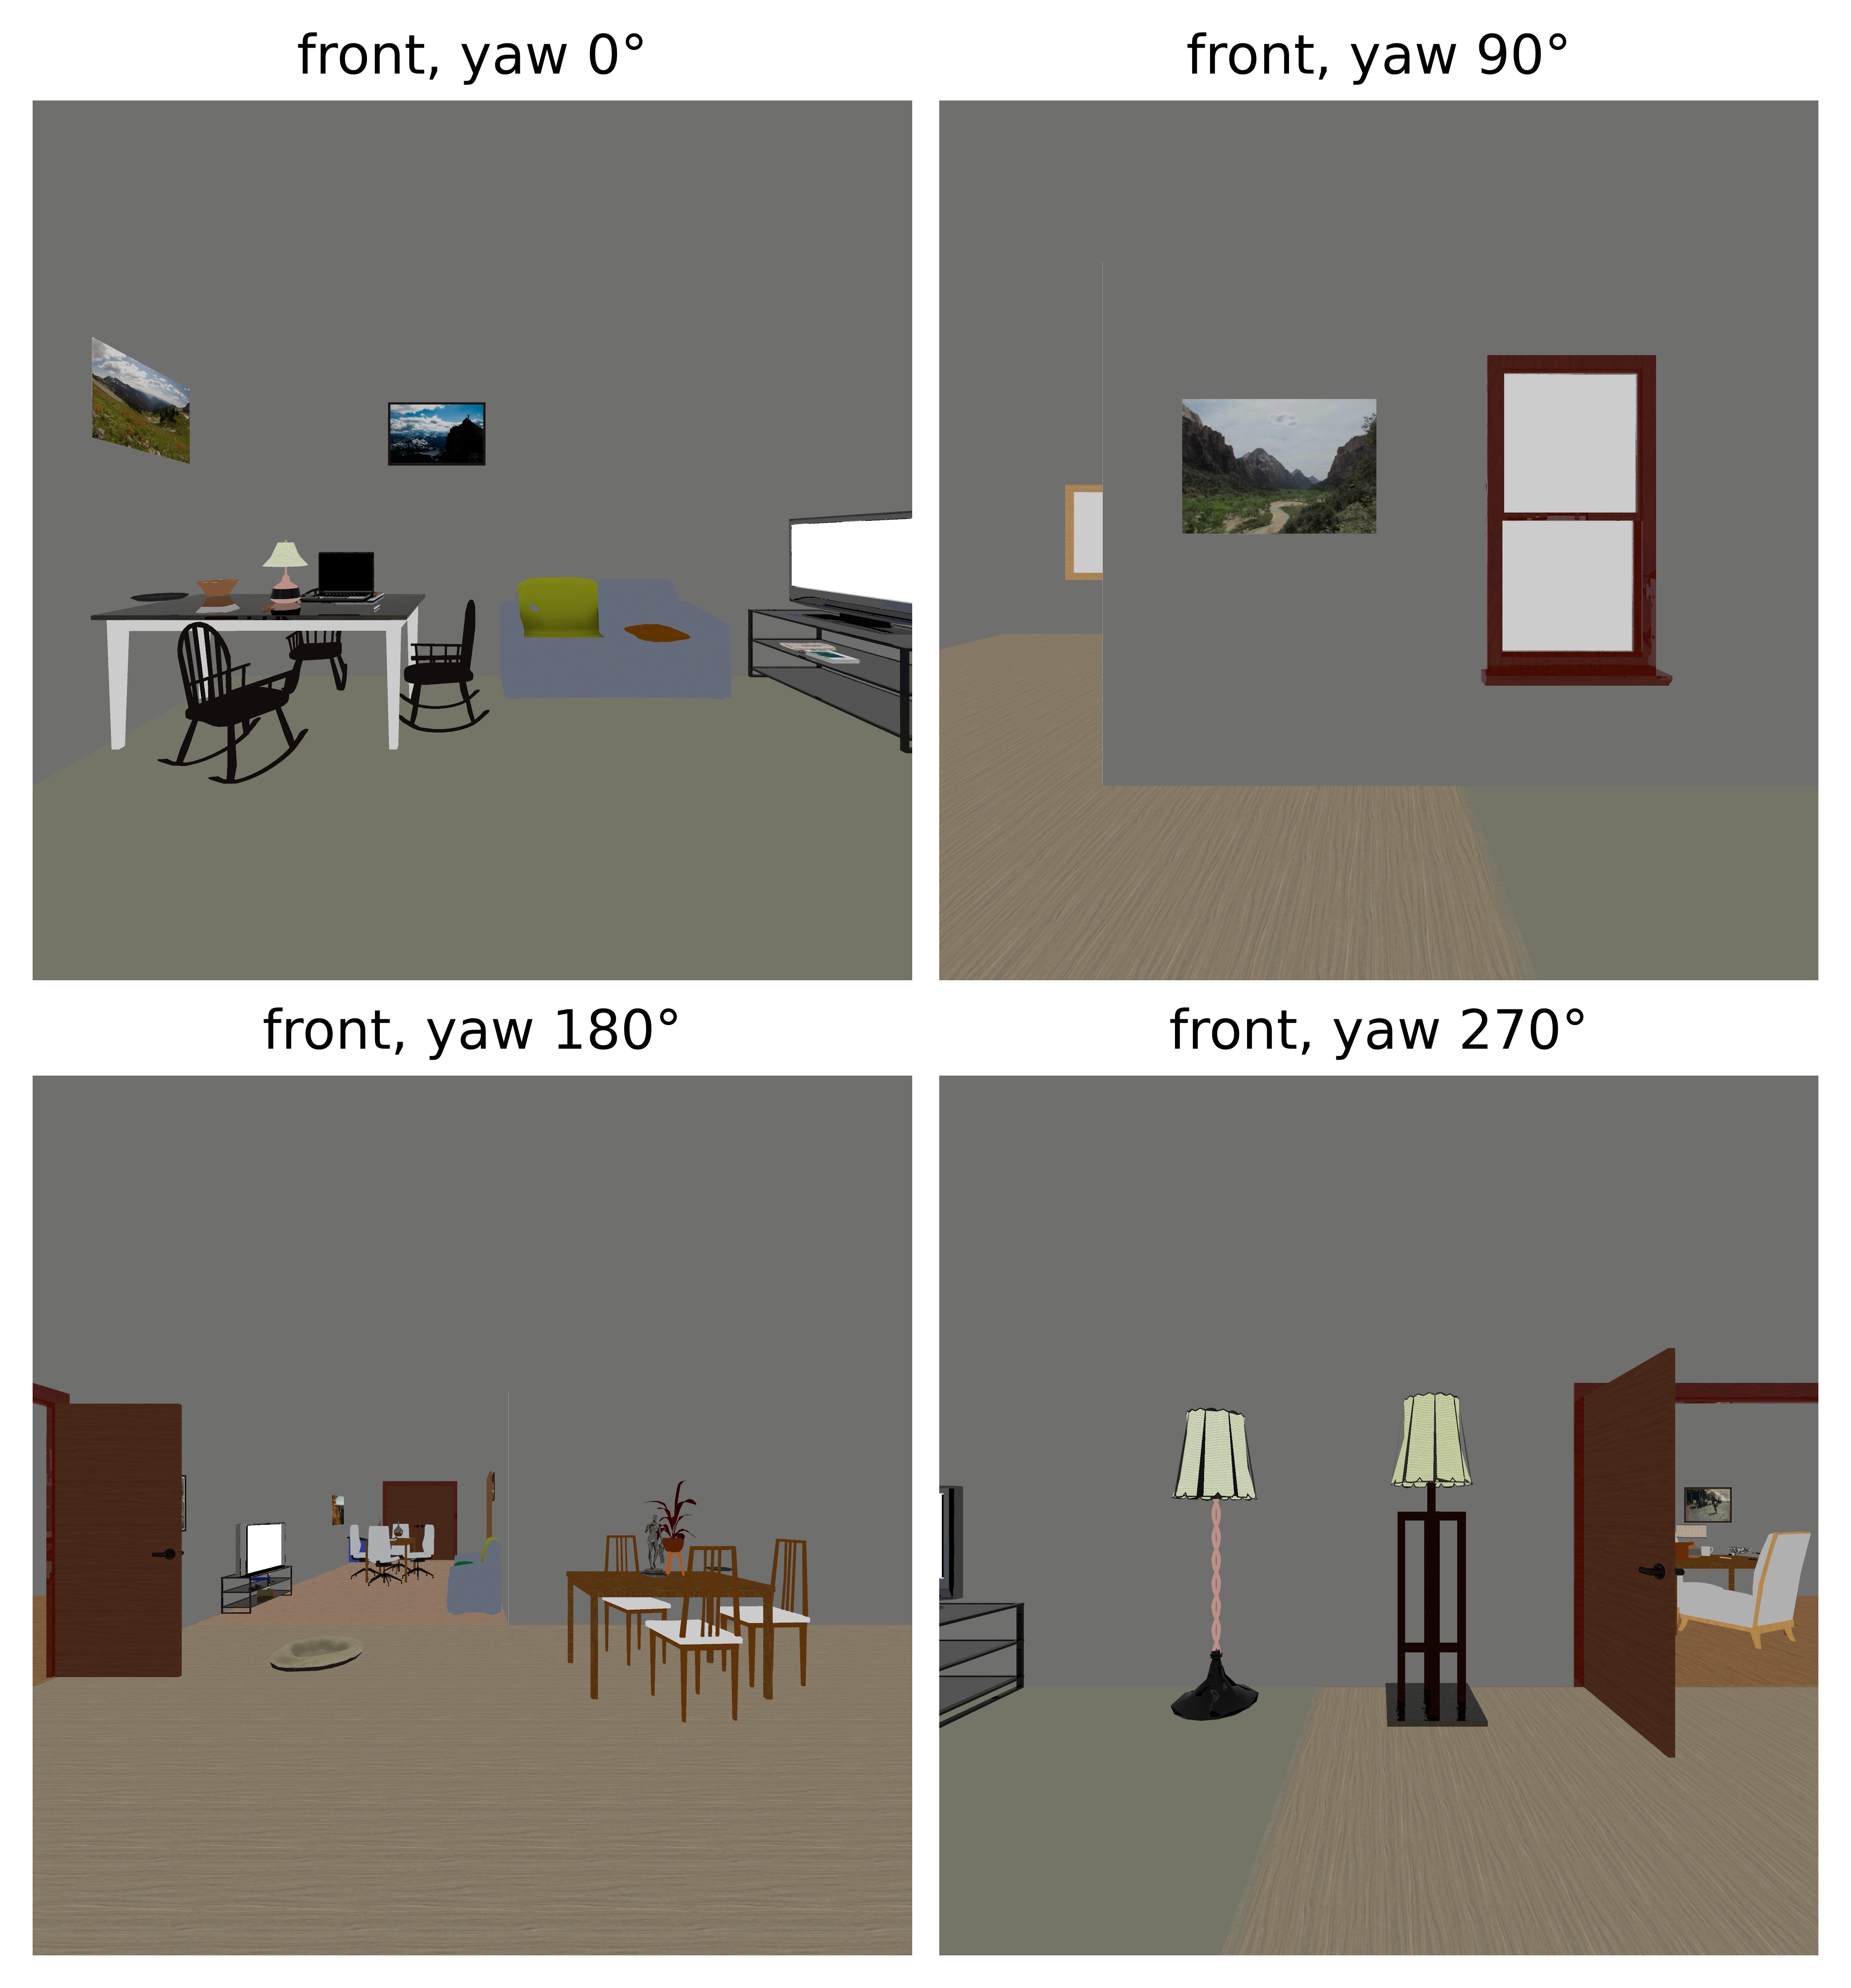
A real scene, a camera rig
dataset = hyperlux.datasets.procthor.Train200()
house = hyperlux.load_scene(dataset["ProcTHOR-Train-1"].reference, preserve_instances=True)
rig = hyperlux.HyperLux(width=2048, height=2048, batch_size=4, num_probes=32, cameras=(
    CameraSpec("front", (RGB(), Depth(), Segmentation(), Segmentation(labels="semantic"), Normals(), Flow(direction="forward"), FlowStatus(direction="forward"), Probes())),
    CameraSpec("preview", (RGB(),))))
rig.init(house)
P = np.array([-3.92, -5.67, 1.2])
yaws = np.deg2rad([0, 90, 180, 270])
cameras = np.stack([hyperlux.make_camera(P, P + (np.cos(yaw), np.sin(yaw), 0), fov=90, aspect=rig.aspect) for yaw in yaws])
rig.set_cameras(np.repeat(cameras, 2, axis=0))
rig.render()
print(rig.outputs[Depth()].layout)
print(rig.outputs[RGB()].layout.cameras)
show(rig.outputs[RGB()].read()[::2], [f"front, yaw {int(np.degrees(yaw))}°" for yaw in yaws], columns=2, layout="compressed", full_resolution=True)
OutputLayout(shape=(4, 2048, 2048), dtype='float32', axes=('camera', 'height', 'width'), cameras=((0, 'front'), (1, 'front'), (2, 'front'), (3, 'front')), device=(2, 0), block_count=1)
((0, 'front'), (0, 'preview'), (1, 'front'), (1, 'preview'), (2, 'front'), (2, 'preview'), (3, 'front'), (3, 'preview'))
Every output
rig.advance_flow()
cameras = np.repeat(np.stack([hyperlux.make_camera(P + (0.05, 0, 0), P + (np.cos(yaw + 0.02), np.sin(yaw + 0.02), 0), fov=90, aspect=rig.aspect) for yaw in yaws]), 2, axis=0)
rig.set_cameras(cameras)
rig.render()
view = {descriptor: rig.outputs[descriptor].read()[0] for descriptor in rig.outputs if descriptor != Probes()}
valid = view[FlowStatus(direction="forward")] == hyperlux.FlowStatus.VALID
show([np.where(np.isfinite(view[Depth()]), view[Depth()], np.nan), view[Normals()] * 0.5 + 0.5,
      np.ma.masked_equal(view[Segmentation()], 0xFFFFFFFF) % 20, np.ma.masked_equal(view[Segmentation(labels="semantic")], 0xFFFFFFFF) % 20,
      np.ma.masked_where(~valid, np.linalg.norm(view[Flow(direction="forward")], axis=-1))],
     ("depth", "normals", "instances", "classes", "forward flow"), columns=2, size=3.6, layout="compressed", full_resolution=True)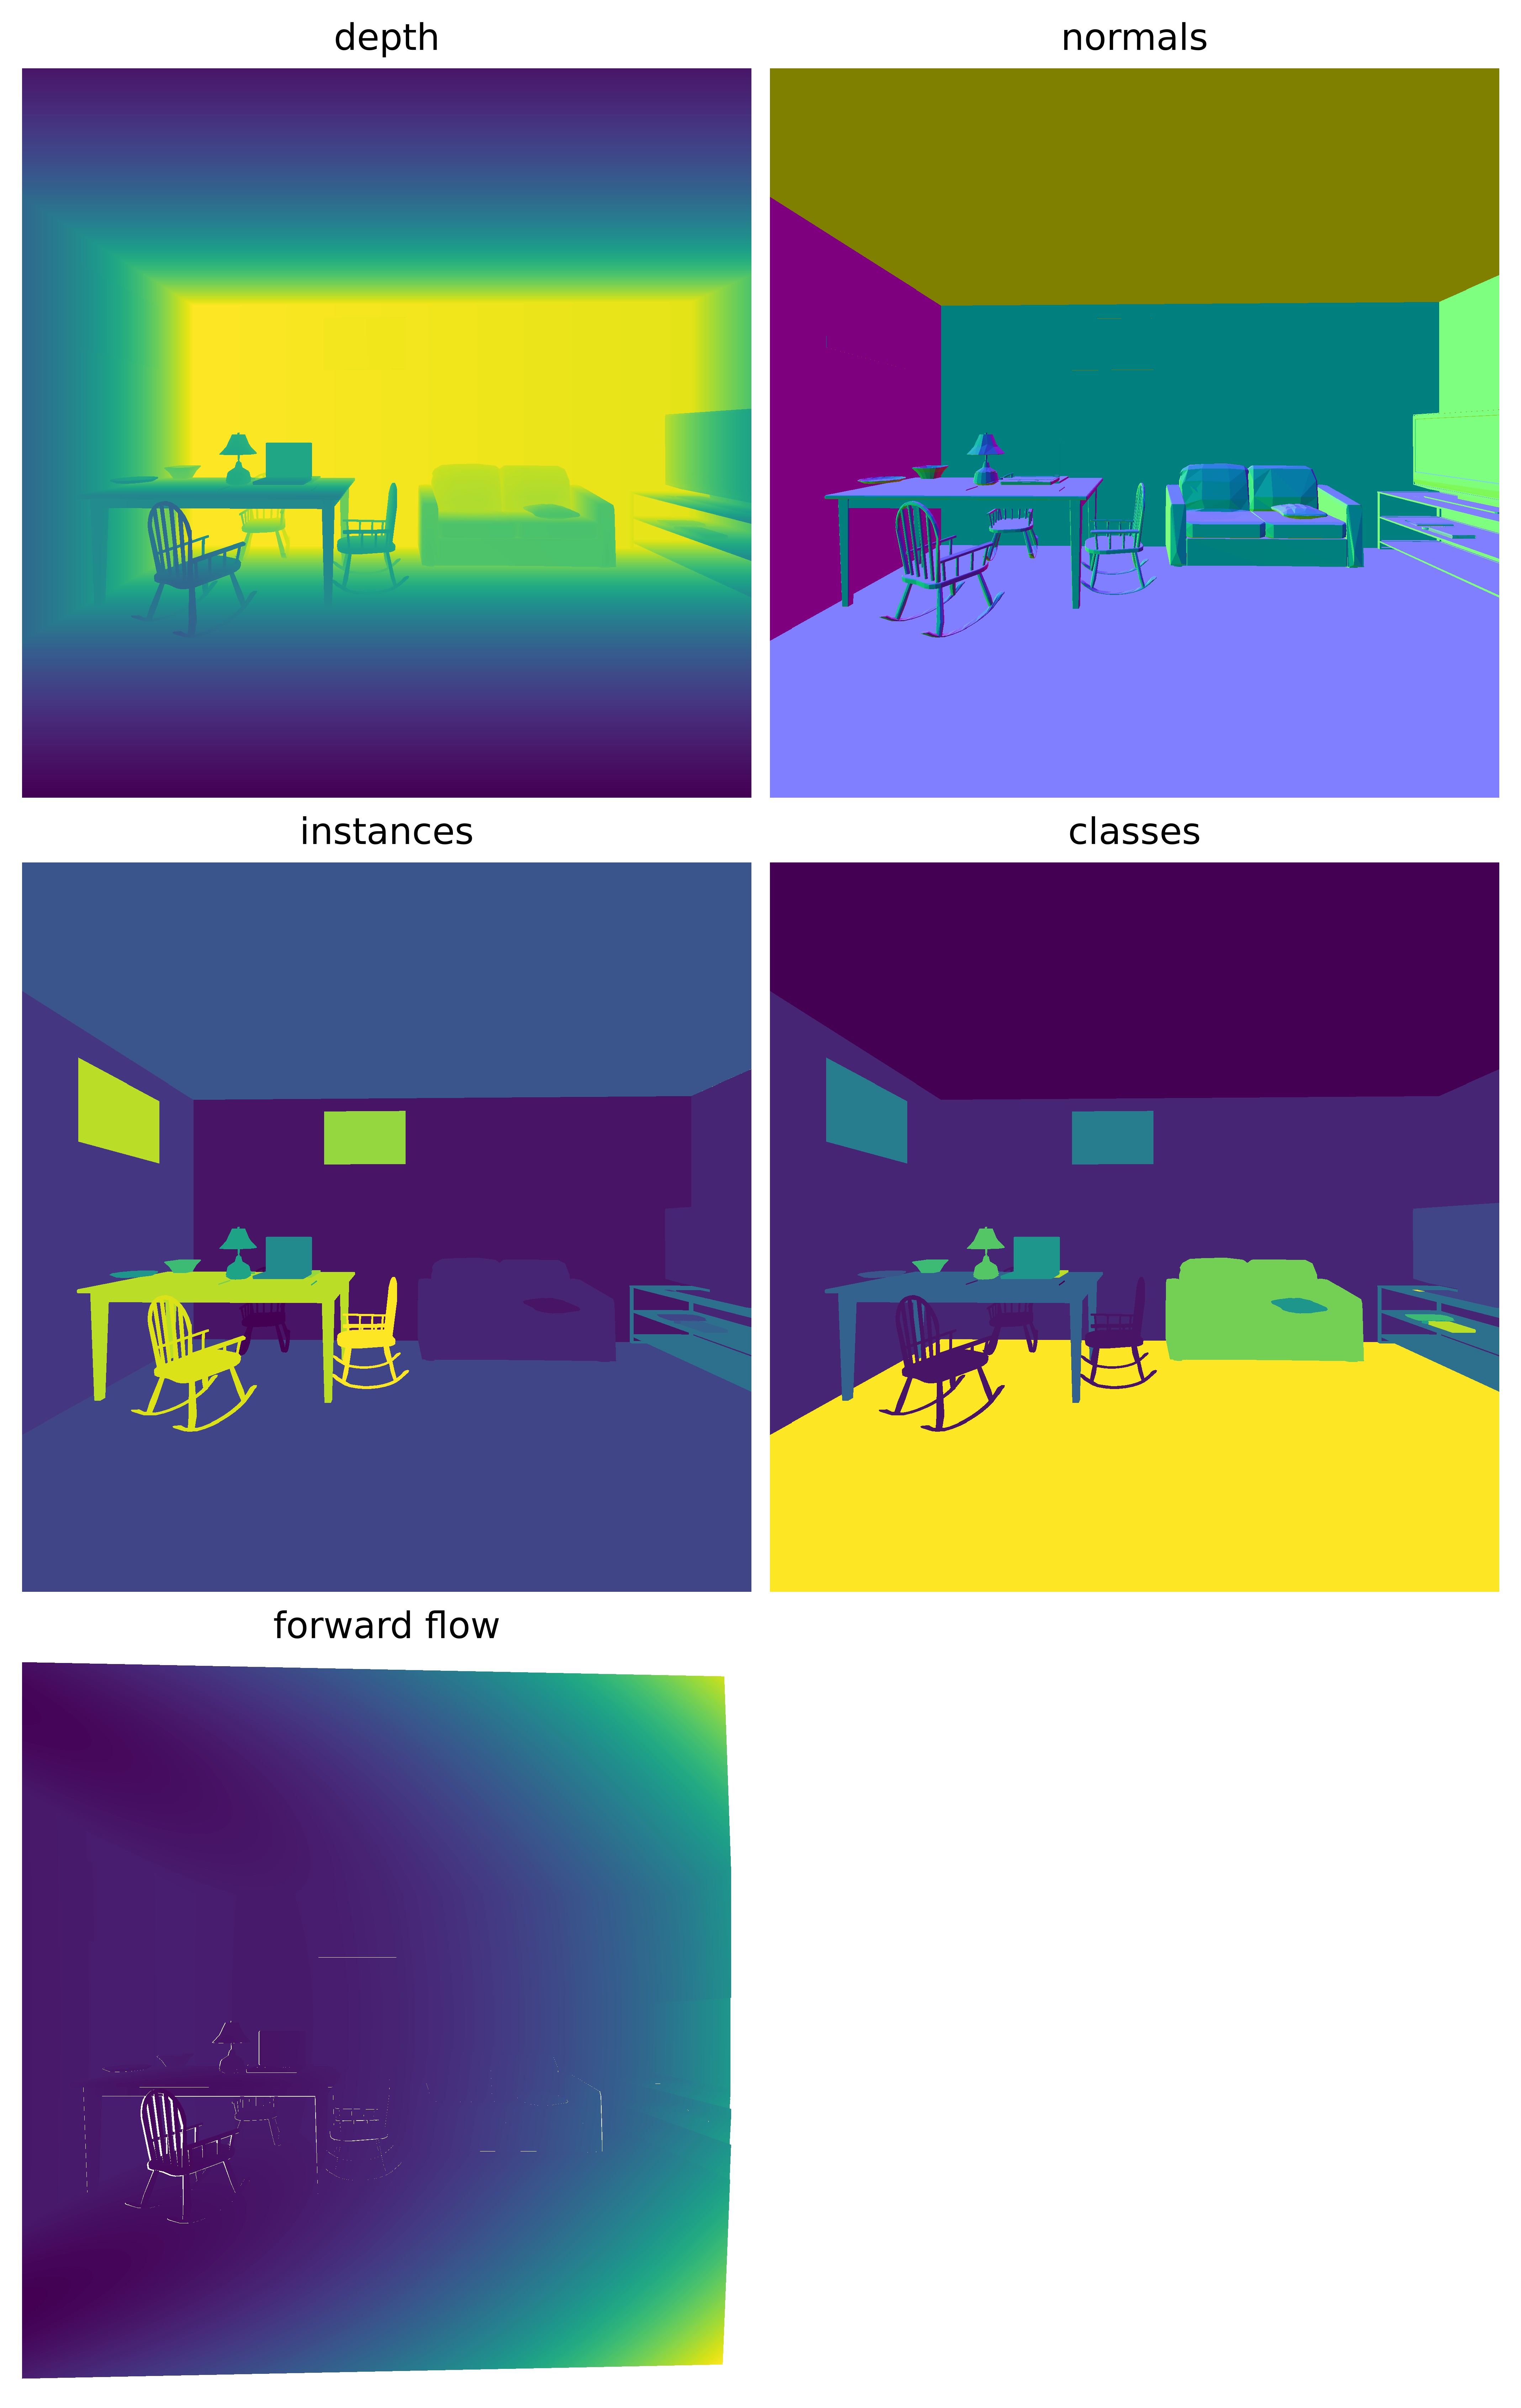
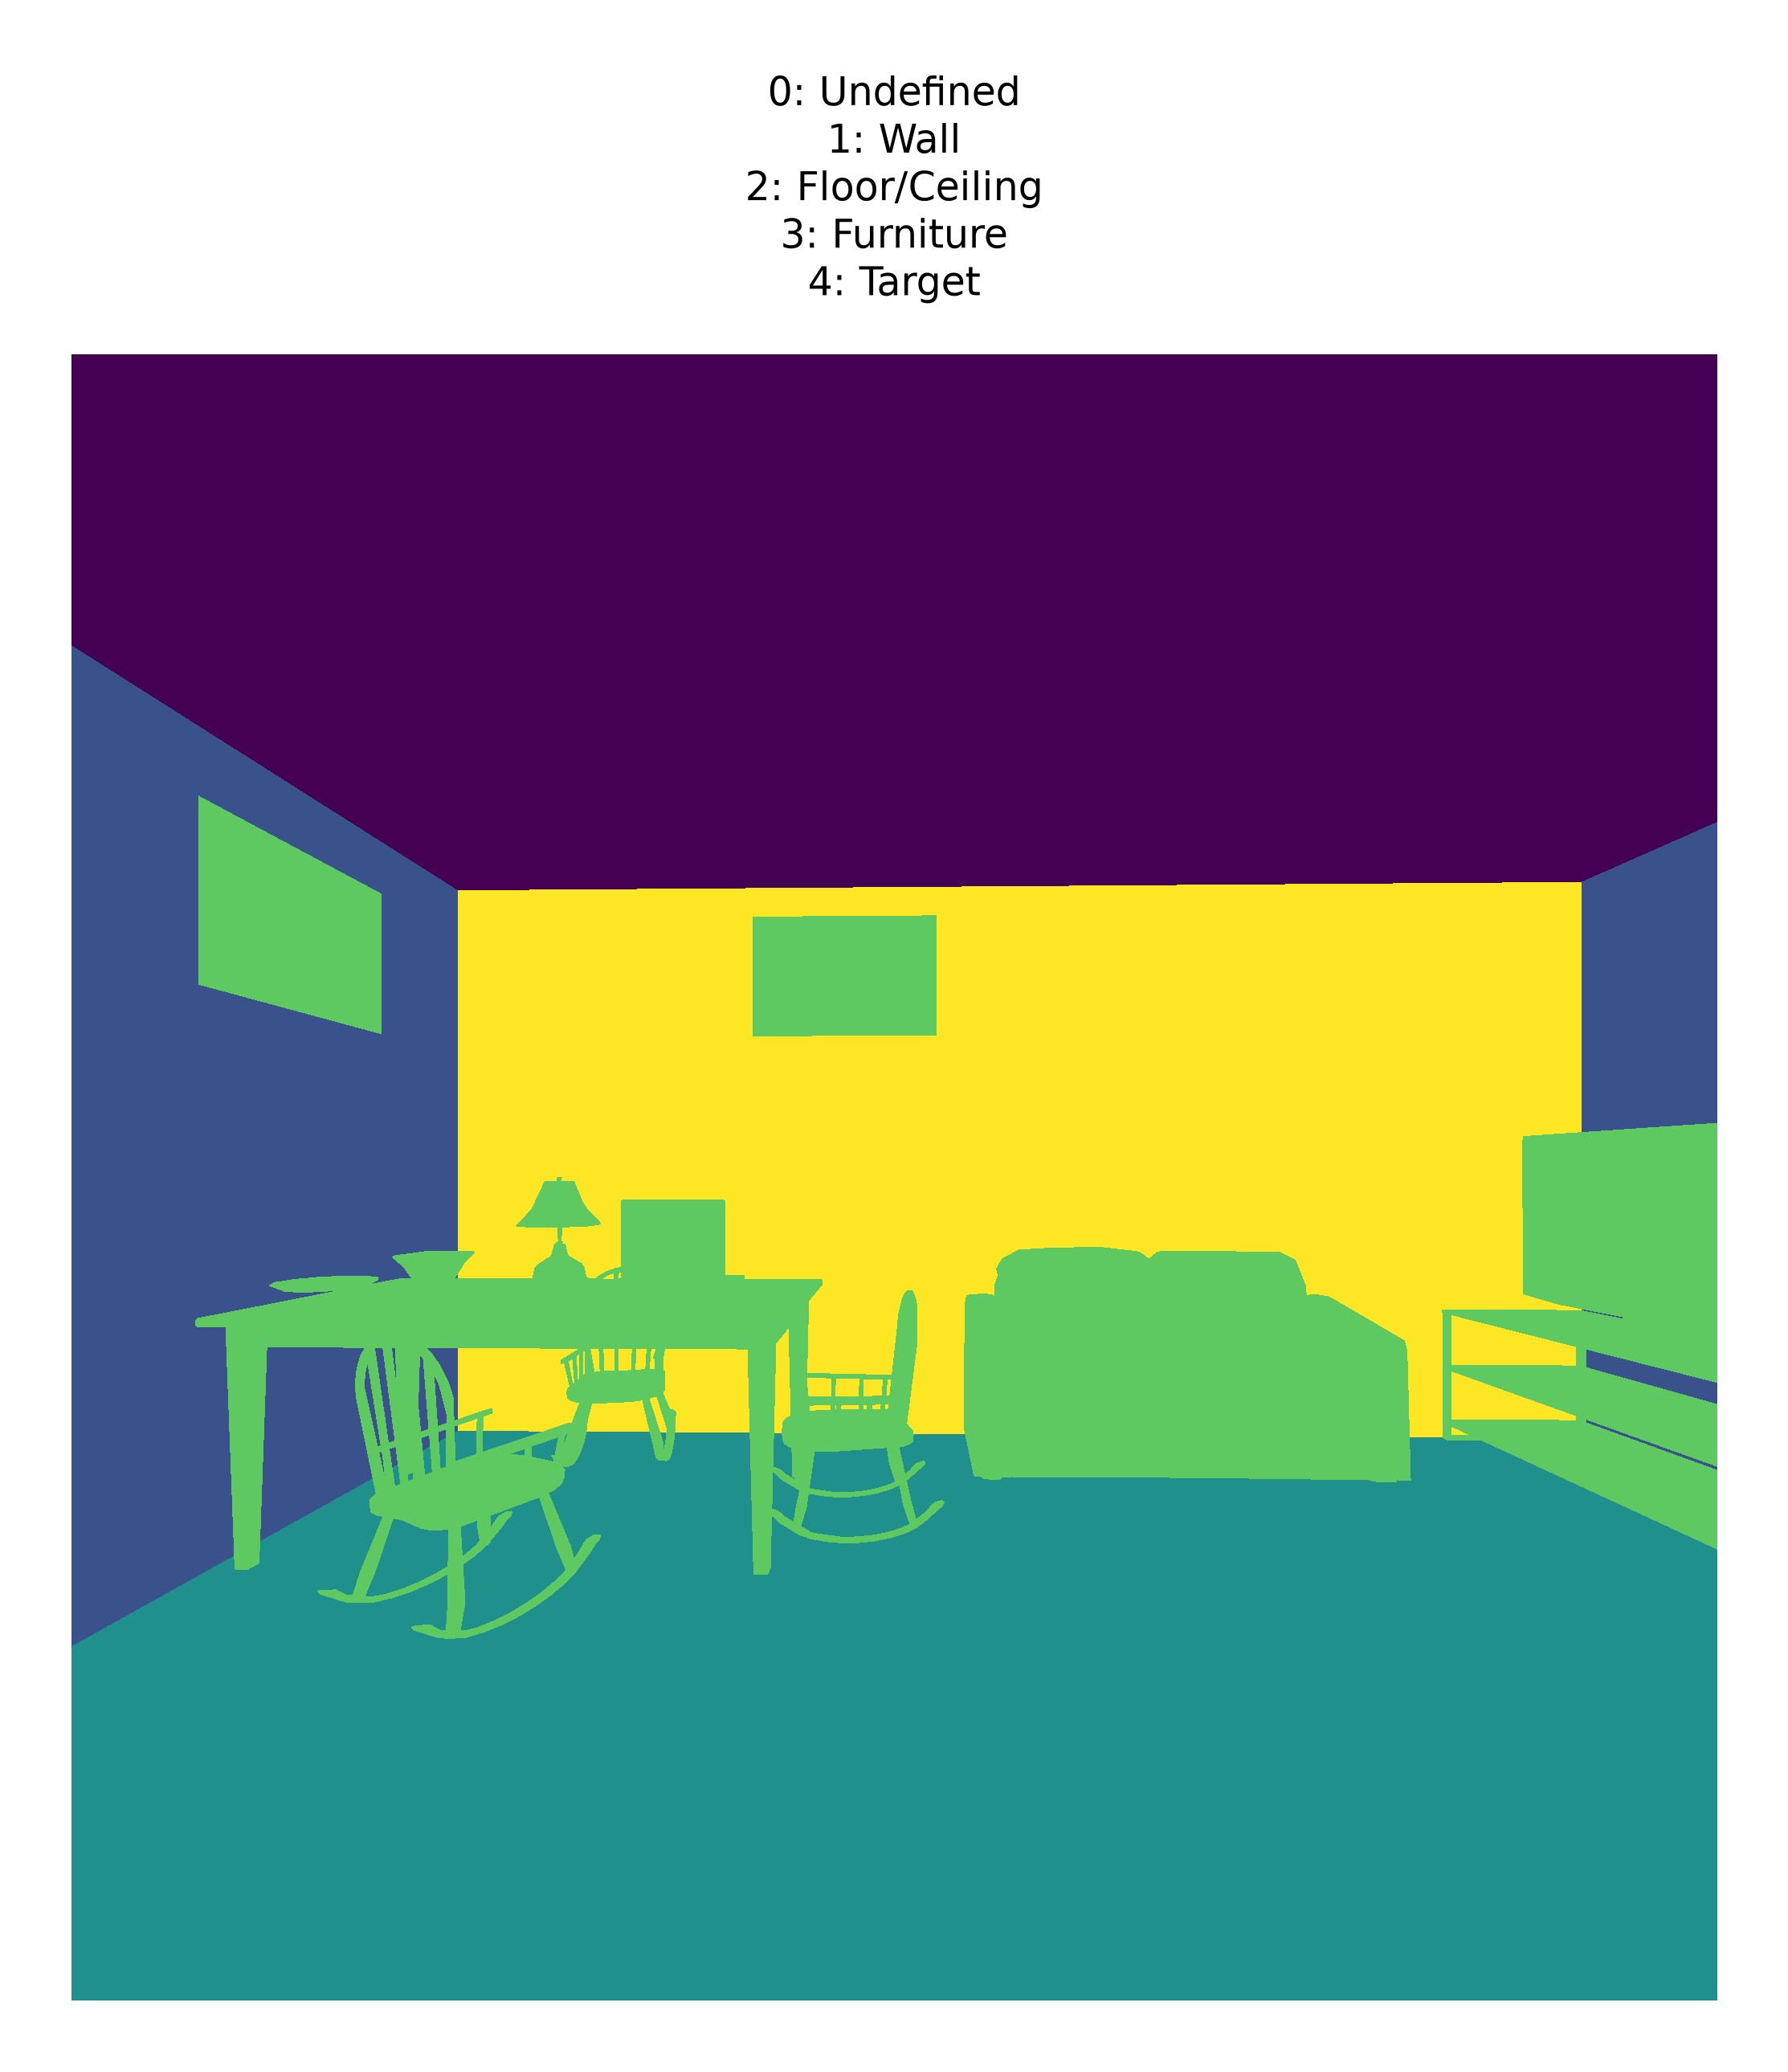
Labels
classes, instances = view[Segmentation(labels="semantic")], view[Segmentation()]
print(house.segmentation_taxonomy, {house.segmentation_classes[int(label)]: int((classes == label).sum()) for label in np.unique(classes) if label != 0xFFFFFFFF})
center = house.instance_object(int(instances[rig.height // 2, rig.width // 2]))
print("center pixel:", house.object_name(center))
coarse = {label: {"Undefined": 0, "Wall": 1, "Floor": 2, "Ceiling": 2}.get(name, 3) for label, name in house.segmentation_classes.items()}
house.remap_segmentation_classes(coarse, taxonomy="coarse", classes={0: "Undefined", 1: "Wall", 2: "Floor/Ceiling", 3: "Furniture", 4: "Target"})
house.set_object_segmentation_class(center, 4)
rig = hyperlux.HyperLux(config=rig.config)
rig.init(house)
rig.set_cameras(cameras)
rig.render()
with plt.rc_context({"axes.titlesize": 4}):
    show([np.ma.masked_equal(rig.outputs[Segmentation(labels="semantic")].read()[0], 0xFFFFFFFF)], ["\n".join(f"{label}: {name}" for label, name in house.segmentation_classes.items())], columns=1, full_resolution=True)
ai2thor-hab {'Undefined': 1275591, 'Bowl': 2777, 'Chair': 71522, 'Plate': 2052, 'DiningTable': 75684, 'Television': 61259, 'Painting': 80931, 'Laptop': 15854, 'RemoteControl': 260, 'Newspaper': 1998, 'CreditCard': 83, 'Book': 3046, 'Pen': 70, 'Pencil': 109, 'Watch': 75, 'Sofa': 139332, 'Pillow': 4691, 'DeskLamp': 7193, 'TVStand': 46876, 'Floor': 1282724, 'Wall': 1122177}
center pixel: Wall#wall|5|0.00|3.51|0.00|8.77
Probes and free space
rig.generate_probe_directions()
rig.probe()
distance, hit = rig.outputs[Probes()].distance.read(), rig.outputs[Probes()].hit.read()
free_space = hyperlux.FreeSpace(house, parameters=hyperlux.FreeSpaceParameters(min_clearance=0.6))
points = free_space.sample(4, seed=0)
Assets and overlays
x500 = conta.resolve({"description": "rigged/x500_optimized_scaled.glb", "hash": "c0fda2143b7a2f0422148aa8f6c4e24db3f8a6e6"})
drone = hyperlux.load_assembly(x500, part_nodes=["body", "prop_0", "prop_1", "prop_2", "prop_3"])
for prop in range(4):
    low, high = drone.object_bounds(prop + 1)
    drone.set_joint(f"prop_{prop}", "revolute", axis=(0, 0, 1), pivot=(low + high) / 2, coordinate=prop)
payload = hyperlux.primitives.box(size=(0.08, 0.08, 0.12), color=(1, 0.8, 0))
payload.name = "payload"
drone.add_part(payload, hyperlux.make_transform(position=(0, 0, -0.15)), parent="body")
drone.set_joint("payload", "prismatic", axis=(0, 0, -1), coordinate=4)
drone.remap_segmentation_classes({0: 3}, taxonomy="coarse", classes=house.segmentation_classes)
print(drone.object_names(), drone.num_coordinates, drone.joint("prop_0"), drone.part_parent(5))
D = P + (0, 0, -0.2)
house.add_assembly(drone, hyperlux.make_transform(position=D + (0.5, 0.9, -0.9)))
pool = hyperlux.AssetPool()
asset = pool.add_assembly(drone)
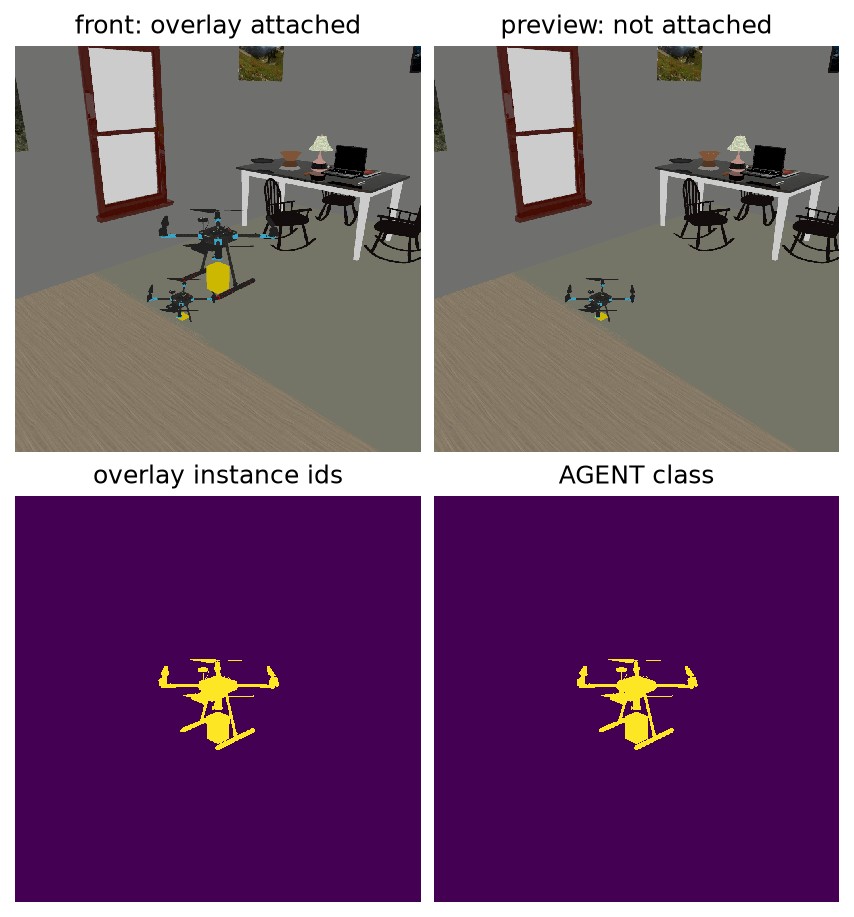
overlay_config = replace(rig.config, width=1024, height=1024, batch_size=1, num_overlays=1, max_overlay_instances=36, max_overlays_per_camera=1, motion_blur_samples=8, dynamic_motion_blur=True)
del rig
overlay = hyperlux.HyperLux(config=overlay_config)
overlay.init(house, asset_pool=pool)
overlay.attach(0, 0)
placement = overlay.spawn(0, asset, hyperlux.Pose(hyperlux.make_transform(position=D)), segmentation_class=hyperlux.AGENT_SEGMENTATION_CLASS)
overlay.set_cameras(np.repeat(overlay.camera(position=D + (-1.2, -1.2, 0.7), look_at=D, fov=55)[None], 2, axis=0))
overlay.update()
overlay.render()
ids = house.num_instances + placement.overlay * overlay.config.max_overlay_instances + placement.first_slot + np.arange(placement.num_parts)
print(placement, ids)
show([*overlay.outputs[RGB()].read(), np.isin(overlay.outputs[Segmentation()].read()[0], ids), overlay.outputs[Segmentation(labels="semantic")].read()[0] == hyperlux.AGENT_SEGMENTATION_CLASS],
     ("front: overlay attached", "preview: not attached", "overlay instance ids", "AGENT class"), columns=2, layout="compressed")
['body', 'prop_0', 'prop_1', 'prop_2', 'prop_3', 'payload'] 5 ('revolute', array([0., 0., 1.], dtype=float32), array([-0.17878559, -0.17474456, 0.11214785], dtype=float32), 0) 0
OverlayPlacement(overlay=0, first_slot=0, num_parts=6, _generation=0, _renderer=11) [295 296 297 298 299 300]
Articulated motion blur
def state(t):
    base = hyperlux.make_transform(position=D + (0, 0, 0.05 * np.sin(2 * t)), orientation_wxyz=(np.cos(t / 2), 0, 0, np.sin(t / 2)))
    coordinates = [150 * t, -150 * t, 150 * t, -150 * t, 0.1 + 0.1 * np.sin(3 * t)]
    camera = overlay.camera(position=D + (-1.2 * np.cos(t / 3), -1.2 * np.sin(t / 3), 0.7), look_at=D, fov=55)
    return base, coordinates, np.repeat(camera[None], 2, axis=0)


def motion_frames():
    for t in np.arange(0, 4, 1 / 30):
        (base_open, coordinates_open, cameras_open), (base_close, coordinates_close, cameras_close) = state(t), state(t + 0.5 / 30)
        overlay.set_pose(placement, hyperlux.Pose(base_open), hyperlux.Pose(base_close), coordinates=coordinates_open, coordinates_close=coordinates_close)
        overlay.set_motion_blur_cameras(cameras_open, cameras_close)
        overlay.update()
        overlay.render()
        yield overlay.outputs[RGB()].read()[0]


video(motion_frames(), "hyperlux_motion.mp4")Bulk posing on the GPU
overlay.despawn(placement)
placements = [overlay.spawn(0, asset) for _ in range(5)]
batch = overlay.placement_batch(placements)
device = torch.device("cuda" if overlay.backend == "optix" else "cpu")
stream = torch.cuda.current_stream(device).cuda_stream if device.type == "cuda" else 0
angles = torch.linspace(0, 2 * torch.pi, 6, device=device)[:-1]
rest = torch.eye(4, device=device)[:3].repeat(5, 1, 1)
rest[:, :, 3] = torch.as_tensor(D, dtype=torch.float32, device=device) + 0.5 * torch.stack((angles.cos(), angles.sin(), 0.3 * (2 * angles).sin()), dim=1)
spin = torch.tensor([150, -150, 150, -150, 0], device=device)
overlay.set_cameras(torch.as_tensor(np.repeat(overlay.camera(position=D + (-1.8, -1.4, 0.9), look_at=D, fov=65)[None], 2, axis=0), device=device), stream=stream)


def swarm_frames():
    frame = torch.empty(overlay.outputs[RGB()].layout.shape, dtype=torch.uint8, device=device)
    for i in range(120):
        t = i / 30
        bases = rest.clone()
        bases[:, 2, 3] += 0.1 * (2 * t + angles).sin()
        overlay.set_pose(batch, hyperlux.Pose(bases), coordinates=spin.expand(5, 5) * t, stream=stream)
        overlay.update_launch()
        overlay.render_launch()
        overlay.outputs[RGB()].read(out=frame, stream=stream)
        yield frame[0].cpu().numpy()


start = time.perf_counter()
swarm_video = video(swarm_frames(), "hyperlux_swarm.mp4")
print(f"{120 / (time.perf_counter() - start):.0f} frames/s including encoding on {device}, render stream {overlay.render_stream:#x}")
live = torch.from_dlpack(overlay.outputs[RGB()].blocks[0])
print(live.shape, live.dtype, live.device, torch.from_dlpack(overlay.outputs[RGB()].packed.blocks[0]).dtype)
swarm_video
10 frames/s including encoding on cuda, render stream 0x55083d50
torch.Size([2, 1024, 1024, 4]) torch.uint8 cuda:0 torch.uint32
Scene catalogs
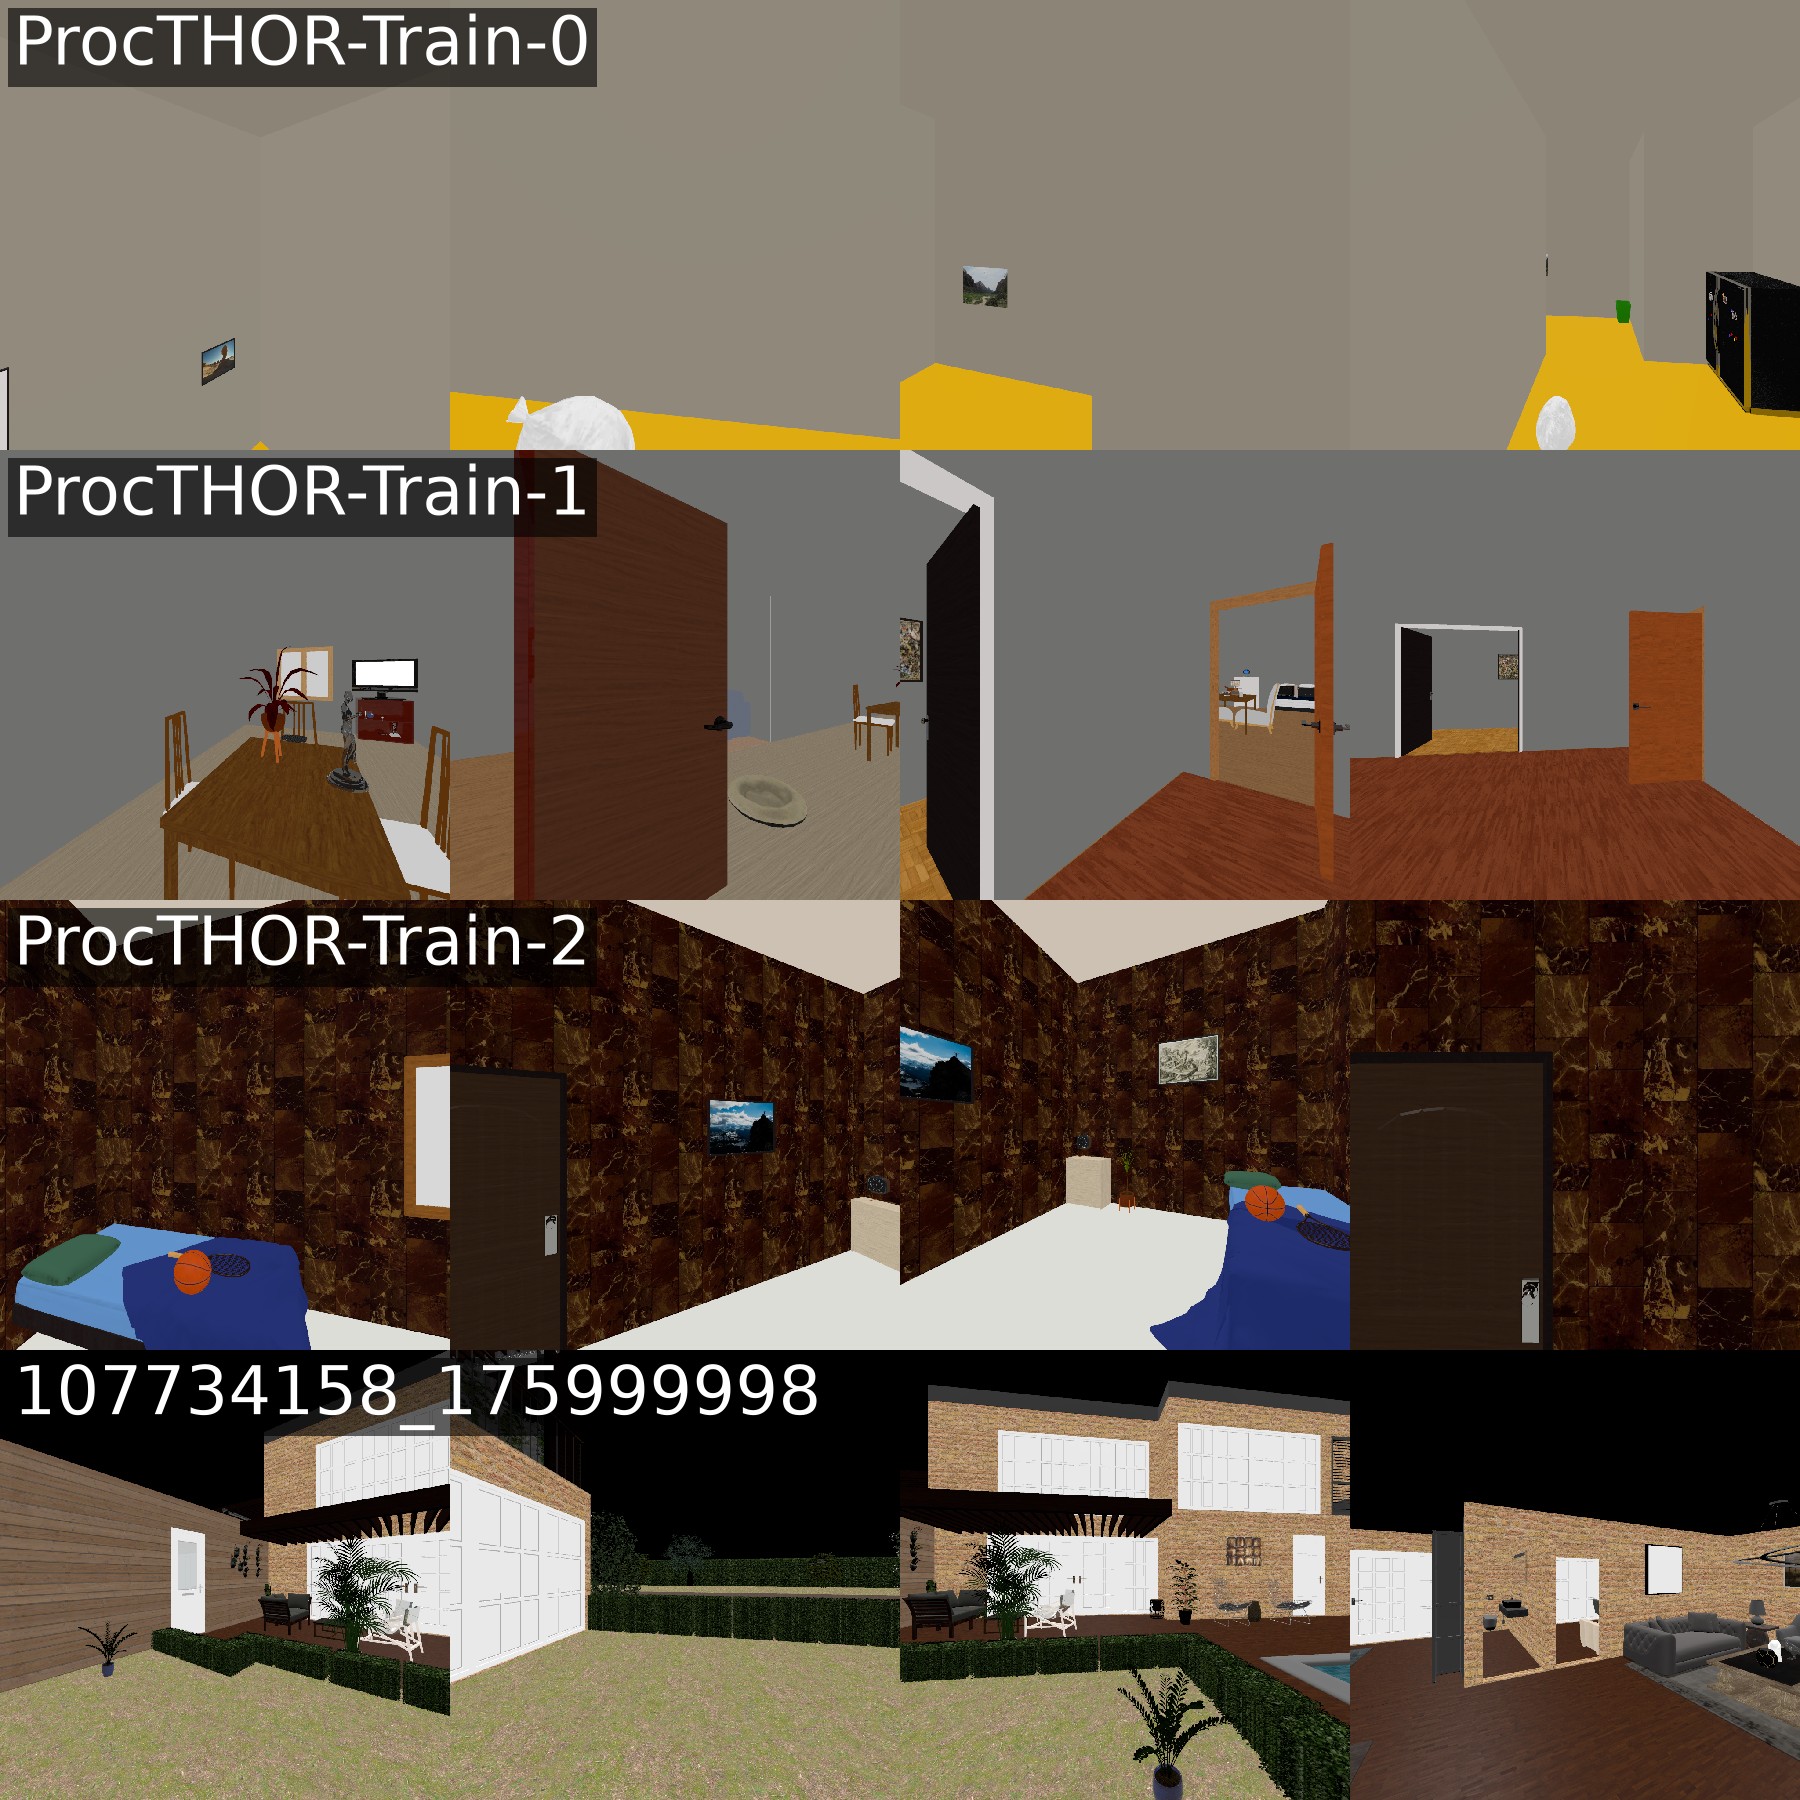
train = hyperlux.datasets.procthor.Train200()
validation = hyperlux.datasets.hssd.Val43()
print(train.name, train.source, train.split, len(train), train[0].id, train[0].reference)
print(validation.name, validation.source, validation.split, len(validation), validation[0].id, validation[0].reference)
entries = (train[0], train[1], train[2], validation[0])
rng = np.random.default_rng(0)
figure, axes = plt.subplots(len(entries), 4, figsize=(12, 3 * len(entries)), dpi=150, squeeze=False)
figure.subplots_adjust(left=0, right=1, bottom=0, top=1, wspace=0, hspace=0)
for entry, row in zip(entries, axes):
    scene = hyperlux.load_scene(entry.reference)
    viewer = hyperlux.HyperLux(config=replace(renderer.config, batch_size=4))
    viewer.init(scene)
    positions = hyperlux.FreeSpace(scene, parameters=hyperlux.FreeSpaceParameters(min_clearance=0.8)).sample(4, seed=0)
    yaws = rng.uniform(-np.pi, np.pi, 4)
    viewer.set_cameras(np.stack([
        viewer.camera(position=position, look_at=position + (np.cos(yaw), np.sin(yaw), 0), fov=90)
        for position, yaw in zip(positions, yaws)
    ]))
    viewer.render()
    for axis, image in zip(row, viewer.outputs[RGB()].read()):
        axis.imshow(image, interpolation="nearest")
        axis.axis("off")
    figure.text(0.03, 0.97, entry.id, transform=row[0].transAxes, va="top", color="white", fontsize=32,
                bbox={"facecolor": "black", "alpha": 0.6, "edgecolor": "none", "pad": 3})
with plt.rc_context({"savefig.pad_inches": 0}):
    plt.show()
procthor_train_200 ai2thor-hab/ProcTHOR train 200 ProcTHOR-Train-0 conta:3ee4771c22b54fa7bb57022ac2eb5a015f387b4d
hssd_val_43 hssd/hssd-hab val 43 107734158_175999998 conta:e5e59b08d09e1192a2a176d05f8006c5d5c21b5f